METRIC Lab
Modeling, Evolution, Trajectory Planning, Robotics, Integration, and Control
We develop principled models and methods to measure, understand, predict, and shape the evolution of complex dynamical and robotic systems.
Campus image 1 of 3
Research Themes
Modeling
Learning-based and principled models for complex dynamical systems.
Evolution
Understanding and predicting how dynamical systems evolve over time.
Trajectory Planning
Planning feasible and efficient motions for robotic systems.
Robotics
Learning, modeling, and control for real-world robotic systems.
Integration
Connecting modeling, prediction, planning, and control into unified systems.
Control
Reliable control methods for complex dynamical and robotic systems.
Selected Publications
View all publications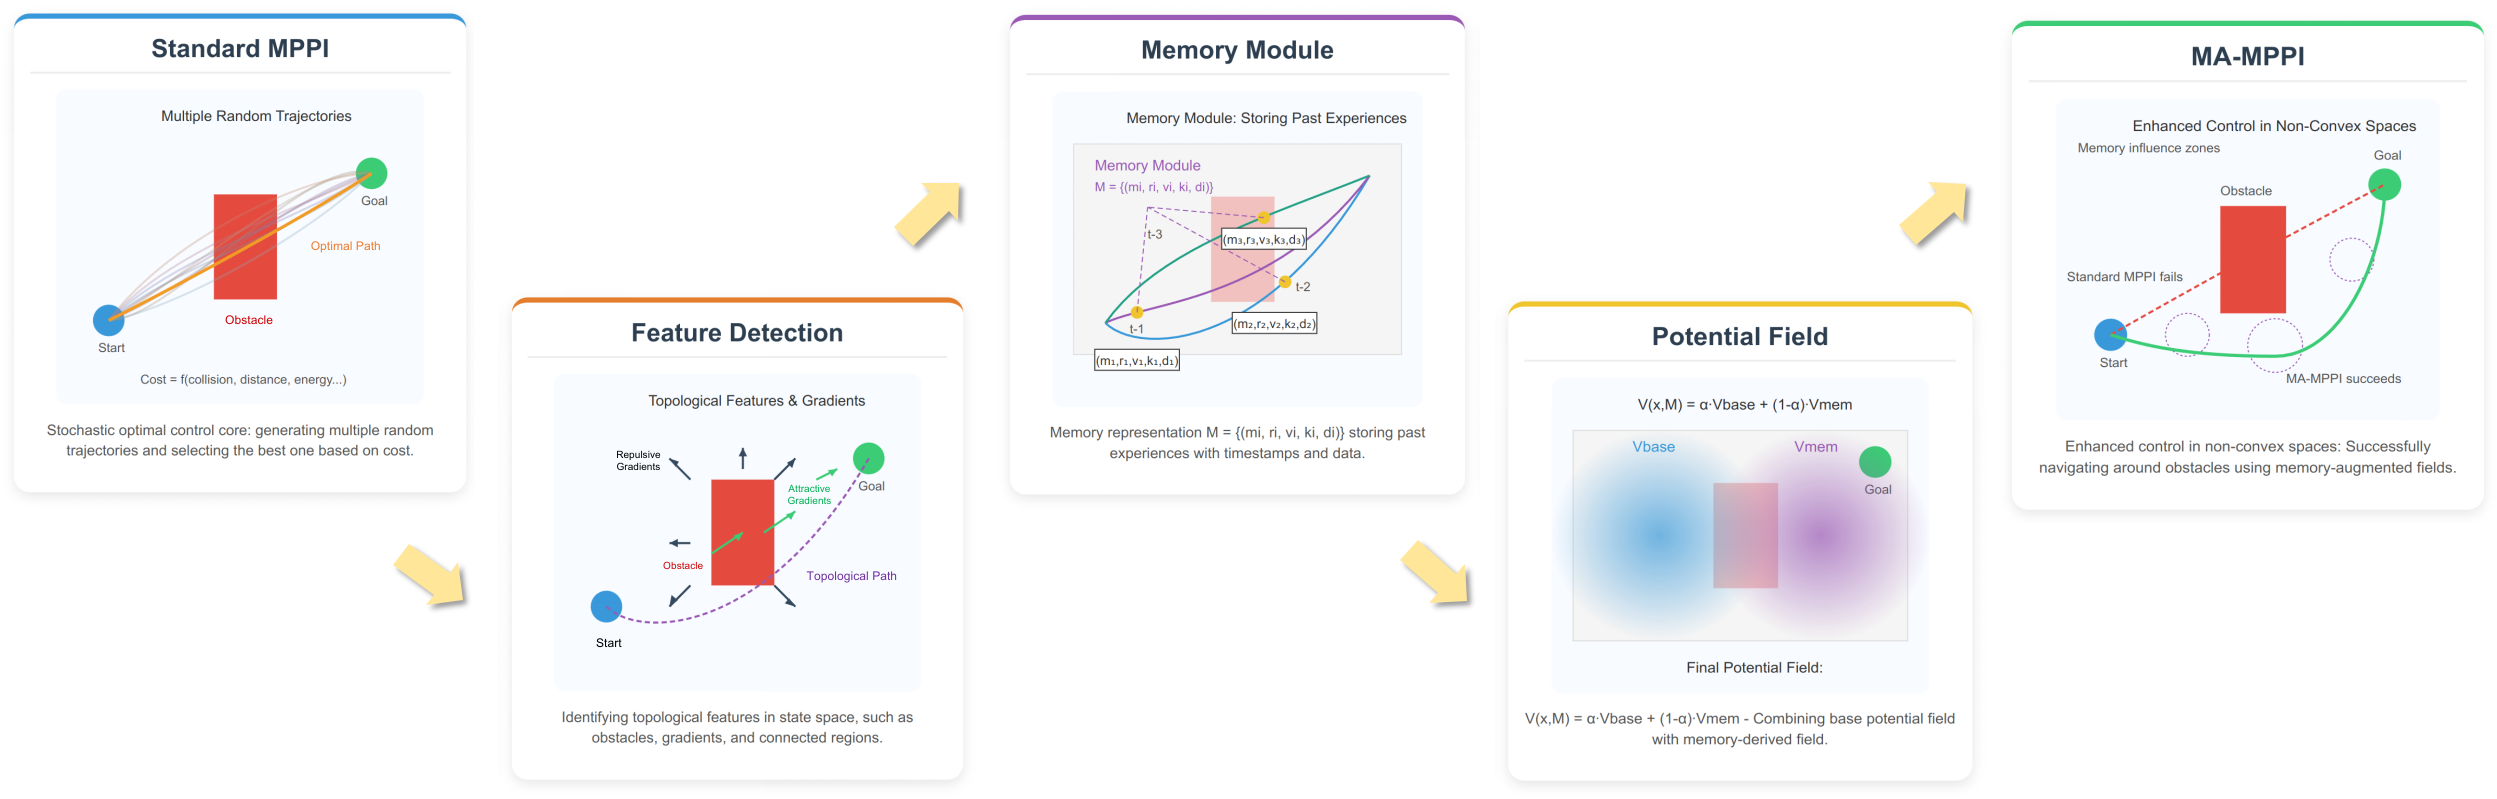
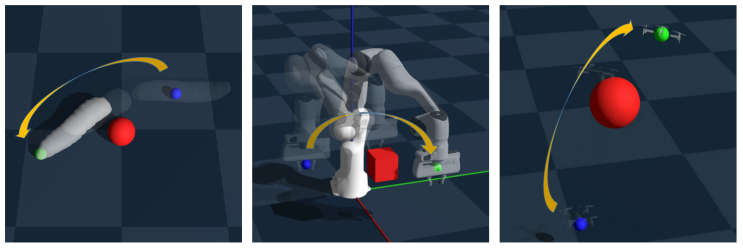
Memory-Augmented Potential Field Theory: A Framework for Adaptive Control in Non-Convex Domains
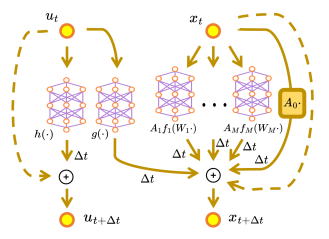
Learning Dynamics under Environmental Constraints via Measurement-Induced Bundle Structures
ControlSynth Neural ODEs: Modeling Dynamical Systems with Guaranteed Convergence
On delay-dependent conditions of ISS for generalized Persidskii systems
On input-to-output stability and robust synchronization of generalized Persidskii systems
On nonlinear robust state estimation for generalized Persidskii systems
Latest News
Our team received the National First Prize in the Simulation Technology Track of the 19th Advanced Robotics and Simulation Technology Competition.
Our team project was named an Outstanding Team in the Jiangsu division of the 14th Entrepreneurship Jiangsu Science and Technology Entrepreneurship Competition and the 15th China Innovation and Entrepreneurship Competition.
Our paper "Generalizable Neural Observer Design with Learned Riemannian Metrics for State Estimation" received the NCAA 2026 Best Paper Award.
Our paper "Contracting Learning-Based Observer for UAV State Estimation Subject to Disturbances" received the ICAC 2026 Best Conference Paper Award.
Our paper "Learning and Current Prediction of PMSM Drive via Differential Neural Networks" was selected an ESI Highly Cited Paper.
Received the ICML 2026 Gold Reviewer Award.
Our paper "Robust Path Tracking for Vehicles via Continuous-Time Residual Learning: An ICODE-MPPI Approach" was accepted by CoDIT 2026.
Our paper "A Posteriori Second-Order Guarantees for Bolza Problems via Collocation" was accepted by IEEE Control Systems Letters.